DWGAL-07
VEX Robotics, Team 44448D Matrix
Captain, lead designer and lead programmer of my school's first team to qualify for the VEX World Championship.
Role
Team captainLead designerLead programmer
When
2019 to 2025
Tools
C++PROSLemLibFusion 360PIDOdometryPneumatics
Results
VEX Worlds qualifierExcellence AwardDesign Award
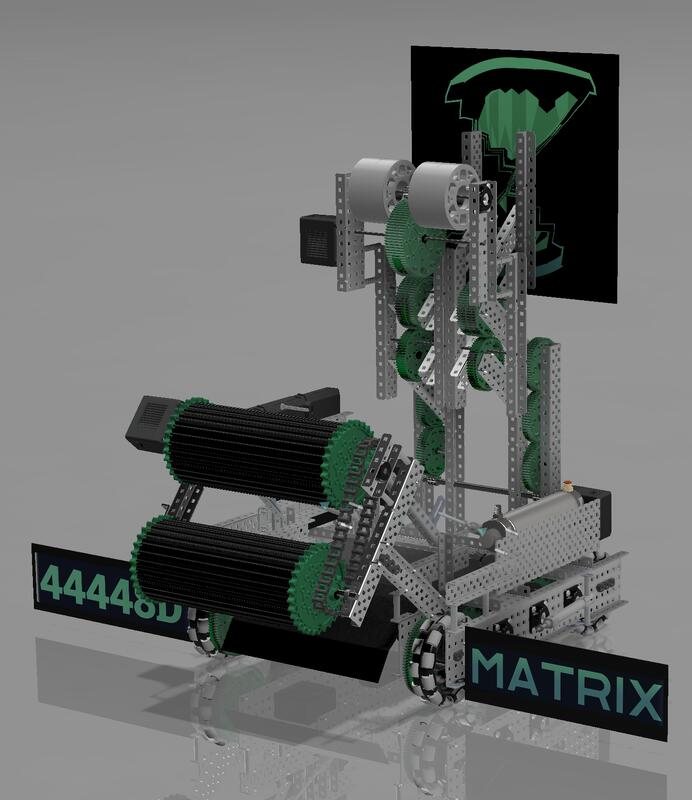
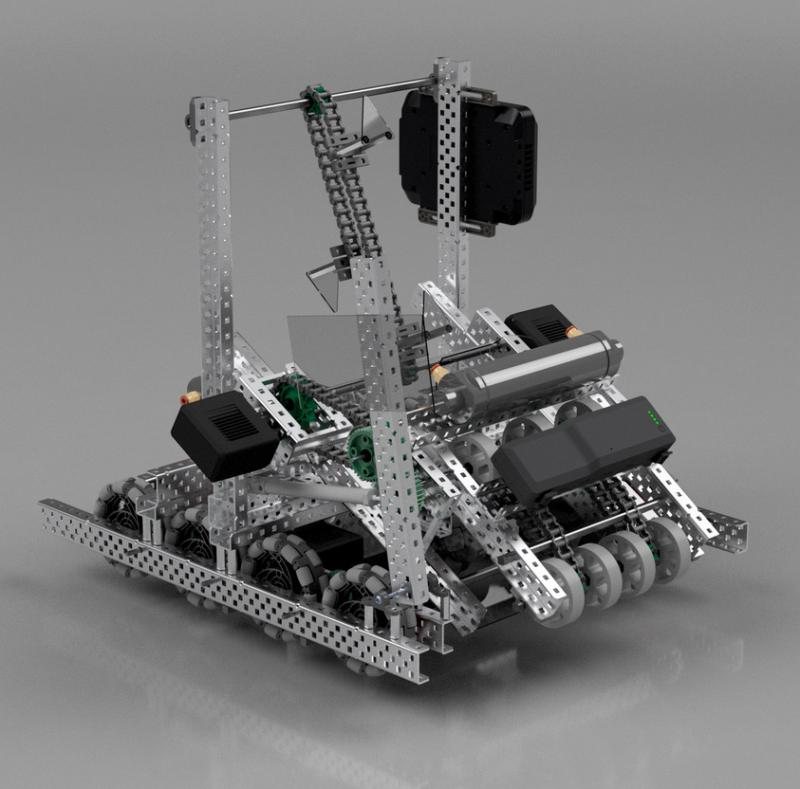
Mechanical
- Owned the robot from CAD to the built machine across several seasons: Tipping Point, Spin Up, Over Under and High Stakes.
- Geared drivetrains, chain-and-sprocket intakes and lifts, and pneumatic mechanisms, all packaged inside the size limit.
- Iterated the tracking-wheel mounts through several design cycles, scoring each for compactness and durability.
- C-channel flush mounts and cut polycarbonate plates where stock parts didn't fit.
Autonomous control
The part I'm proudest of is the positioning system. The robot knows where it is on the field at all times, which is what makes the autonomous routines repeatable.
- Odometry. Two unpowered tracking wheels on rotary encoders, one along the robot and one across it, fused with an inertial sensor to give position and heading in real time.
- Path following. Pure pursuit and boomerang controllers on top of the odometry.
- PID tuning. Tuned for consistent routines with little drift over a full match.
- Code. C++ with PROS and LemLib. The High Stakes code is on GitHub.
TRY ITClick the field. The robot drives there on a PID loop and logs its track.
Leading the team
- Led the school's first team to qualify for the VEX World Championship, by winning nationals in Thailand.
- Excellence Award and Design Award at Thailand Nationals. One earlier season we lost Excellence by a single point.
- About 20 hours a week during the season.
- Coached a VEX IQ team to the Amaze Award and refereed 12 tournaments.